01
Perceive
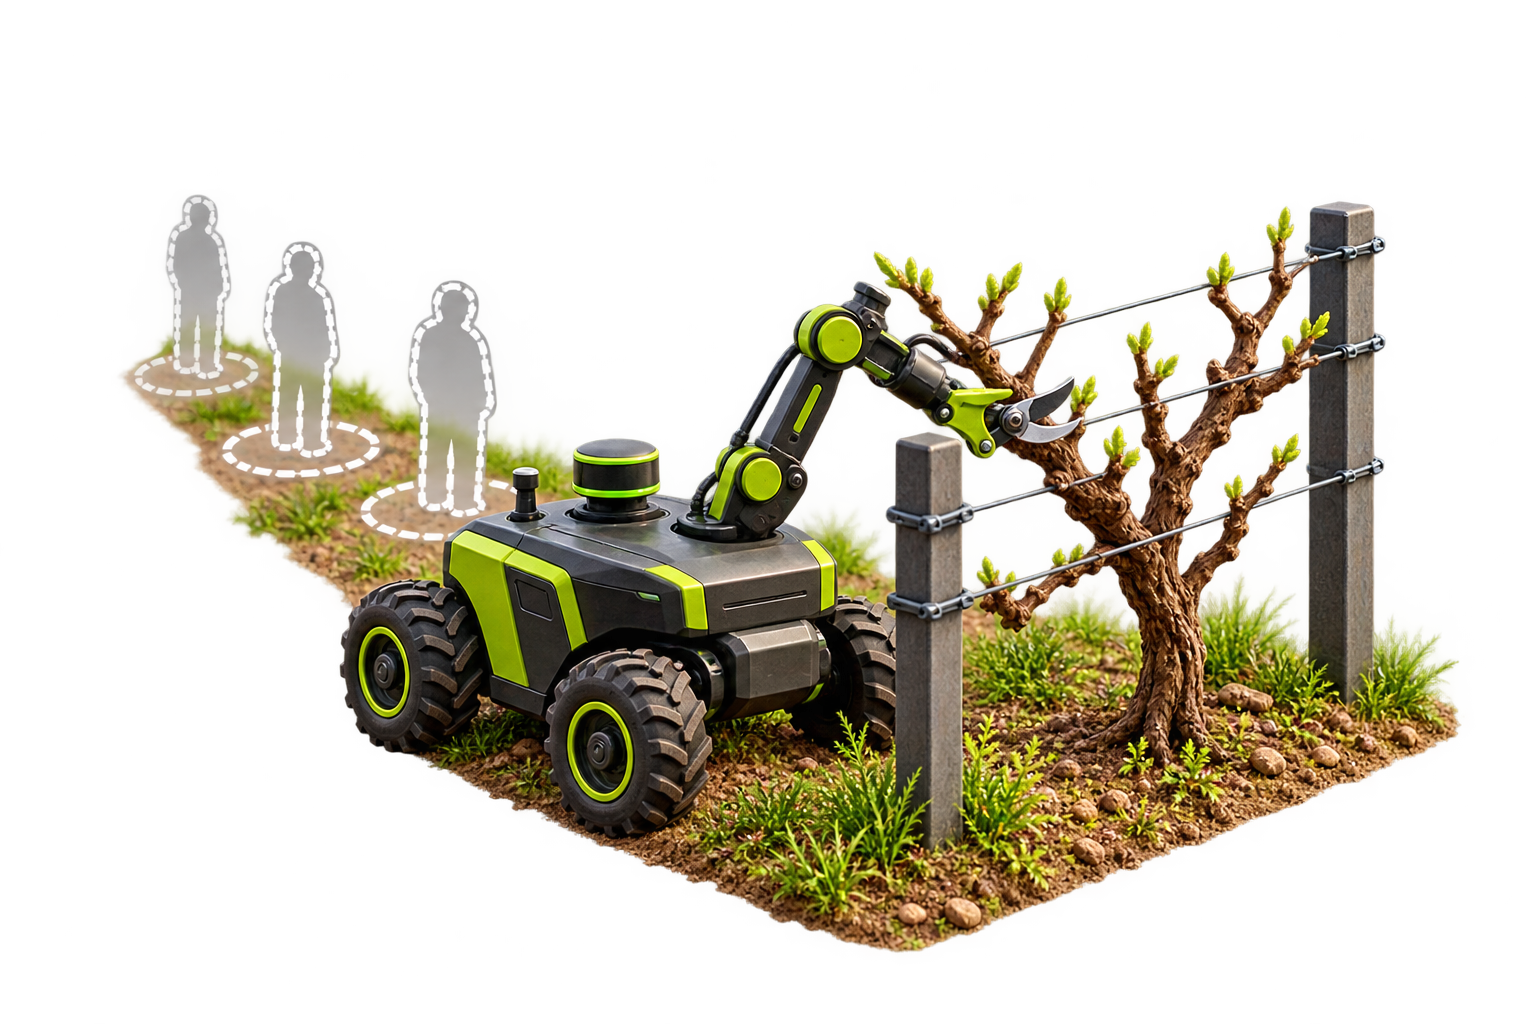
Stereo and depth cameras map the vine structure and identify trunks, cordons, canes and candidate cut points.
 OXOBOT
Start a conversation ↗

Oxobot is an Indian physical AI and agricultural robotics startup building fully autonomous precision grape pruning. Our system is being developed to perceive a vineyard, decide where to cut, and execute each cut. Built in Nashik, with the ambition to serve vineyards worldwide.
Fully autonomous field intelligence
Pruning is not simply cutting. It is a time-sensitive biological decision that shapes yield, fruit quality and the next season’s growth. Oxobot is turning that skilled decision into physical intelligence.
Vineyard pruning depends on scarce skilled labour and a narrow seasonal window. A delay can ripple through the entire crop cycle.

Skilled labour is unavailable
›
Pruning gets delayed
›
Crop cycle shifts
›
Quality and yield face risk
›
Farmer income becomes volatile


Oxobot combines vision, agronomy logic and precise robotic action in one continuous loop—designed for Indian vineyards and real outdoor variability.
Stereo and depth cameras map the vine structure and identify trunks, cordons, canes and candidate cut points.

Agronomy rules and Oxobot’s AI convert plant structure into a deliberate, explainable pruning decision.

A controlled cutting mechanism autonomously executes each selected cut with precision.
Oxobot has already developed and demonstrated an autonomous agricultural ground robot powered by an in-house robotics and autonomy stack. Precision pruning builds on that working foundation.


These are development targets from Oxobot’s current pruning programme—not yet commercial performance claims.
Targeting fully autonomous pruning with no dedicated field crew.

Target coverage in a 12-hour operating day.

AI-guided decisions designed for repeatable pruning quality.
Clear, field-grounded explanations of pruning automation, vineyard robotics and physical AI—written by the team building the technology.
How a grape-pruning robot perceives vine structure, makes pruning decisions and acts in a real vineyard.
Explore pruning automation ↗ GUIDE 02Why agricultural robots need embodied intelligence, outdoor autonomy and task-aware decision making.
Explore physical AI ↗ GUIDE 03What precision farming means, where autonomous robots fit, and how Oxobot is approaching high-value vineyard work.
Explore precision farming ↗ COMPANY FACTSVerified company, founder, technology, location, achievements and supporter information for media and research.
View company facts ↗Grape-pruning automation in India ↗ · Computer vision for pruning ↗ · द्राक्ष छाटणी रोबोट — मराठी ↗
We welcome conversations with growers, farm leaders, researchers, investors and technology partners.
Collaborate with Oxobot ↗